PhD student at University of Toronto, supervised by Steven Waslander. We're interested in perception and decision-making algorithms that can generalize and adapt to the open world.
Letian Wang 王乐天
Hi there! I'm a Ph.D. student at the University of Toronto, where I am fortunate to be supervised by Prof. Steven Waslander (Nicest Steve Ever!) in the Toronto Robotics and AI Lab. I'm affiliated with Vector Institute. I have been fortunate to do research at/with:
- João Carreira, Andrew Zisserman, and Kaiming He (2026)
- Misha Andriluka, Andrei Zanfir, and Eduard Bazavan (2025)
- Peter Karkus, Seung Wook Kim, Sanja Fidler, and Marco Pavone (2024)
I'm fascinated by intelligent systems that can generalize beyond their training experience and adapt to the open world, much like humans do. I started my research in robotics, and this curiosity has since taken me across multimodal learning, LLM agents, and reinforcement learning. Most recently, I've been working on general-purpose video models [1] and long-term memory for LLM agents [2]. I'm particularly drawn to simple, unified approaches that scale effectively, and I do not get tired when trying to understand how scaling works across data, compute, model architectures, and task complexity.
I have authored 2 books [3] [4], was the awardee of Qualcomm Fellowship 2025, the winner of 2022 CARLA autonomous driving challenge, and won the best paper award honorable mention at RA-L 2021, first prize in the National Challenge Cup, China.
G. Scholar LinkedIn Twitter
I'm looking for industrial positions from 2026.
letianwang0 at gmail dot com
Innovation GenCeption is released with code/weight! Also see my thoughts after building it at Google DeepMind
Press WallStreet Journal and Google AI blog post on our video foundation models (THFM and GenCeption).
Awardee Qualcomm Fellowship Proposal: Spatiotemporal Reasoning for Unified Perception and Prediction World Models
Contributor MiroThinker A state-of-the-art open-source LLM deep research model
2026
New blog post: What's wrong with CV research? Thoughts after attending ECCV 2026.
GenCeption is released! Check it out!
Our book on motion prediction and world model is published by Foundations and Trends in Robotics.
2025
Contributor to MiroThinker, the state-of-the-art open-source deep research model.
Awarded
Qualcomm Fellowship. Thanks you Qualcomm!
Ontario Graduate Scholarship, Canada
SmartPretrain accepted to ICLR, early exploration of scaling laws in motion prediction!
Check out DistillNeRF, perceiving/reconstructing the 3D driving world without any labels or per-scene training!
Passed my PhD qualification, officially a PhD candidate now
LmDrive and SmartRefine get accepted to CVPR
I start my internship in NVIDIA Research Autonomous Vehicle
Research Group.
Invited by zdjszx.com to give a public
course on Intelligent/Generalizable Decision Making in Dense Environment.
Our ASAP-RL on efficient reinforcement learning for
autonomous driving is accepted by RSS.
Our ReasonNet
on end-to-end driving with temporal and global reasoning is accepted by CVPR.
Our book on Social Interactions for Autonomous
Driving is published by Foundations and Trends in Robotics.
One paper received the Best Paper Award - Honorable Mention of RA-L 2021.
National Scholarship, Beihang University
2018
May-Fourth Medal, highest honor for undergraduate at Beihang university, 10 people each year2017
First prize in National Challenge Cup (全国挑战杯一等奖, known as Sci./Tech. Olympics among universities in China)2022.09 - Present

2025 - 2026

Student Researcher at Google DeepMind, with Misha Andriluka, Andrei Zanfir, Eduard Bazavan, João Carreira, Andrew Zisserman, Kaiming He. I am working on unified text-video models.
2025 -

Research intern at MiroMind, with Jifeng Dai and Lidong Bing. I worked on LLM deep research agents, long-term memory, long context and efficient sparse attention. Contributor to MiroThinker, the state-of-the-art open-source deep research model.
2023.09 - 2024.06

Research intern at NVIDIA Research, with Peter Karkus, Seung Wook Kim, Boris Ivanovic, Yue Wang, Sanja Fidler, and Marco Pavone. I worked on self-supervised 3D-aware visual pretraining via generalizable neural radiance field [NeurIPS'24].
2020.10 - 2022.05

Research assistant at the Robotics Institute of Carnegie Mellon University, with Changliu Liu and Yeping Hu. I worked on generalizable motion prediction algorithms in different scenarios, and social interaction for autonomous driving [NeurIPS'21, AAAI'22, Book]
2019.10 - 2020.10

Research assistant at UC Berkeley, with Masayoshi Tomizuka, Liting Sun, and Wei Zhan. I worked on socially-compatible behavior generation for autonomous driving [RA-L'21] (Best Paper Award Honorable Mention)

See my Google Scholar profile for a more up-to-date list.
* denotes equal contribution
Video Generation Models are General-Purpose Vision Learners
Letian Wang, Chuhan Zhang, Rishabh Kabra, Jasper Uijlings, Steven Waslander, Andrew Zisserman, Joao Carreira, Kaiming He, Misha Andriluka, Eduard Gabriel Bazavan, Andrei Zanfir, Cristian Sminchisescu
European Conference on Computer Vision (ECCV 2026)
Can video generation do for vision what LLM did for language? Yes
Webpage • PDF • Code
BeyondSight: Object Permanence for End-to-End Autonomous Driving
Sandro Papais, Letian Wang, M Jain, B Rezaei, Steven L. Waslander
European Conference on Computer Vision (ECCV 2026)
PDF
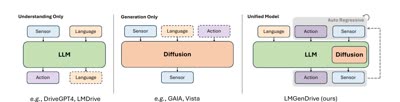
LMGenDrive: Bridging Multimodal Understanding and Generative World Modeling for End-to-End Driving
Hao Shao, Letian Wang, Yang Zhou, Y Hu, Zhuofan Zong, Steven L. Waslander, Wei Zhan, Hongsheng Li
European Conference on Computer Vision (ECCV 2026)
PDF
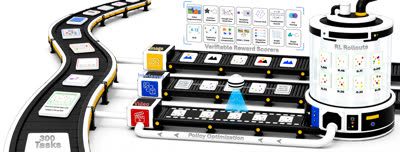
VBVR-Pro: A Scalable and Verifiable Suite for Native Visual Reasoning
J Xu, R Wang, F Pu, M Wang, R Ji, Tong Zhou, C Gu, J Zuo, Han Xiao, Y Geng, Letian Wang, et al.
arXiv preprint arXiv:2608.26105
PDF
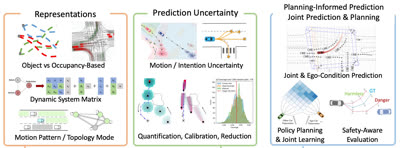
Trends in Motion Prediction Toward Deployable and Generalizable Autonomy: A Revisit and Perspectives
Letian Wang, M A Lavoie, Sandro Papais, B Nisar, Y Chen, W Ding, Boris Ivanovic, et al.
Foundations and Trends in Robotics 13 (1-2), 2026 (Book)
PDF
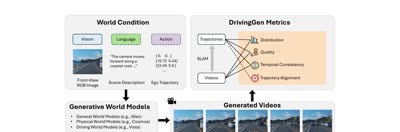
DrivingGen: A Comprehensive Benchmark for Generative Video World Models in Autonomous Driving
Yang Zhou, Hao Shao, Letian Wang, Zhuofan Zong, Hongsheng Li, Steven Waslander
International Conference on Learning Representations (ICLR 2026)
PDF
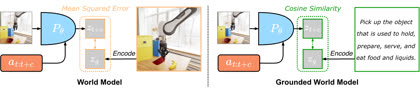
Grounded World Model for Semantically Generalizable Planning
Q Li, L Feng, H Zhang, W Li, Letian Wang, A Alahi, H Soh
arXiv preprint arXiv:2604.11751
PDF
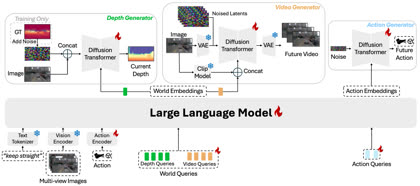
DriveDreamer-Policy: A Geometry-Grounded World-Action Model for Unified Generation and Planning
Yang Zhou, X Wang, Hao Shao, Letian Wang, G Zhao, J Shao, J Zhu, T Yu, Z Zhu, et al.
arXiv preprint arXiv:2604.01765
PDF
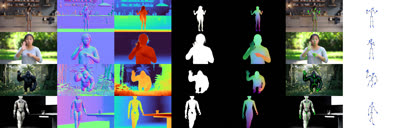
THFM: A Unified Video Foundation Model for 4D Human Perception and Beyond
Letian Wang, Andrei Zanfir, Eduard Gabriel Bazavan, Misha Andriluka, Cristian Sminchisescu
arXiv preprint arXiv:2603.25892
PDF
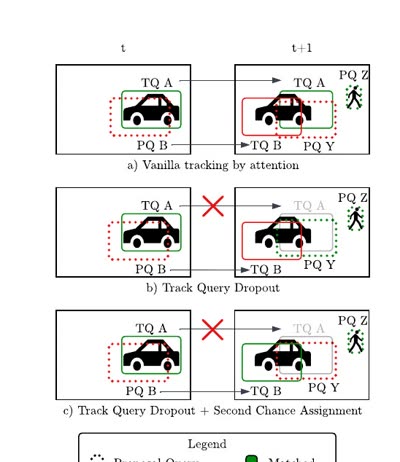
SCATR: Mitigating New Instance Suppression in LiDAR-based Tracking-by-Attention via Second Chance Assignment and Track Query Dropout
Brian Cheong, Letian Wang, Sandro Papais, Steven L. Waslander
IEEE/CVF Winter Conference on Applications of Computer Vision (WACV 2026)
PDF
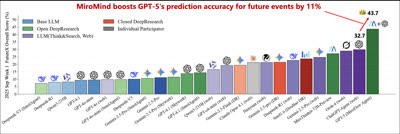
MiroThinker: Pushing the Performance Boundaries of Open-Source Research Agents via Model, Context, and Interactive Scaling
MiroMind Team
arXiv preprint arXiv:2511.11793
Strongest Open-Source LLM Deep Research at the time
PDF
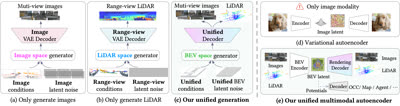
OmniGen: Unified Multimodal Sensor Generation for Autonomous Driving
T Tang, E Ma, X Zhou, Letian Wang, T Yan, X Zhang, K Zhan, P Jia, X Lang, et al.
ACM International Conference on Multimedia (ACM MM 2025)
PDF

ForeSight: Multi-View Streaming Joint Object Detection and Trajectory Forecasting
Sandro Papais, Letian Wang, Brian Cheong, Steven L. Waslander
IEEE/CVF International Conference on Computer Vision (ICCV 2025)
PDF
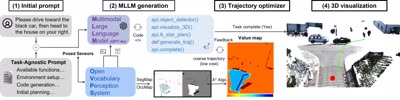
OpenNav: Open-World Navigation with Multimodal Large Language Models
M Yuan, Letian Wang, Steven L. Waslander
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2025)
PDF
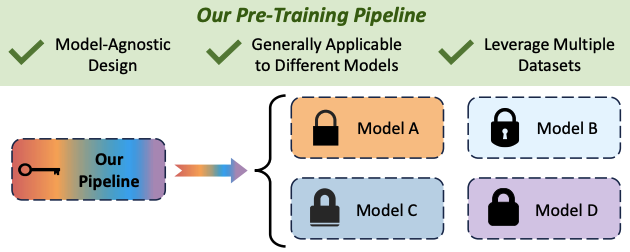
SmartPretrain: Model-Agnostic and Dataset-Agnostic Representation Learning for Motion Prediction
Yang Zhou*, Hao Shao*, Letian Wang*, Steven L. Waslander, Hongsheng Li, Yu Liu
International Conference on Learning Representations (ICLR 2025)
Exploring the Scaling Laws in Motion Prediction
PDF •
DistillNeRF: Perceiving 3D Scenes from Single-Glance Images by Distilling Neural Fields and Foundation Model Features
Letian Wang, Seung Wook Kim, Jiawei Yang, Cunjun Yu,
Boris Ivanovic, Steven L Waslander, Yue Wang, Sanja Fidler, Marco Pavone, Peter Karkus
Advances in Neural Information Processing Systems (NeurIPS 2024)
Exploring Self-Supervised 3D-Aware Visual Pretraining.
Webpage •
PDF •
Video
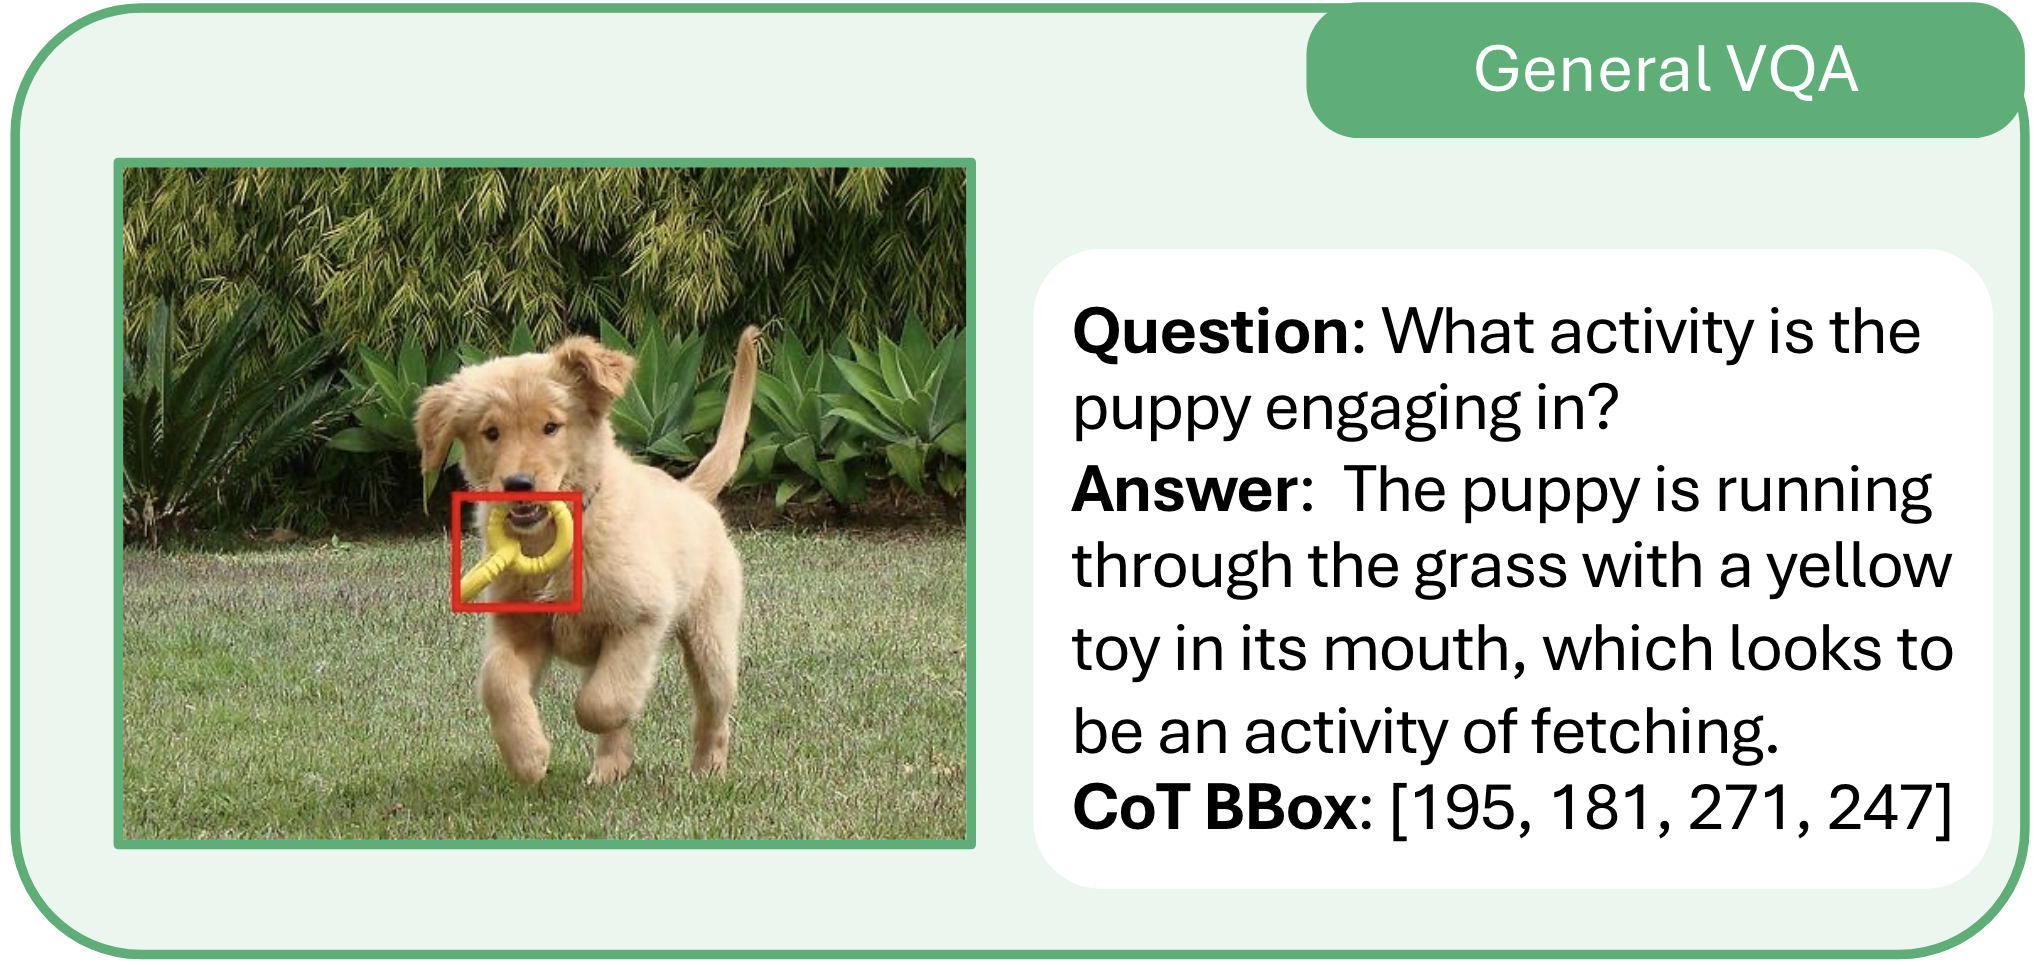
Visual CoT: Advancing Multi-Modal Language Models with a Comprehensive Dataset and Benchmark for Chain-of-Thought Reasoning
Hao Shao, Shengju Qian, Han Xiao, Guanglu Song, Zhuofan Zong, Letian Wang, Yu Liu, Hongsheng Li
Advances in Neural Information Processing Systems (NeurIPS 2024, Spotlight)
PDF •
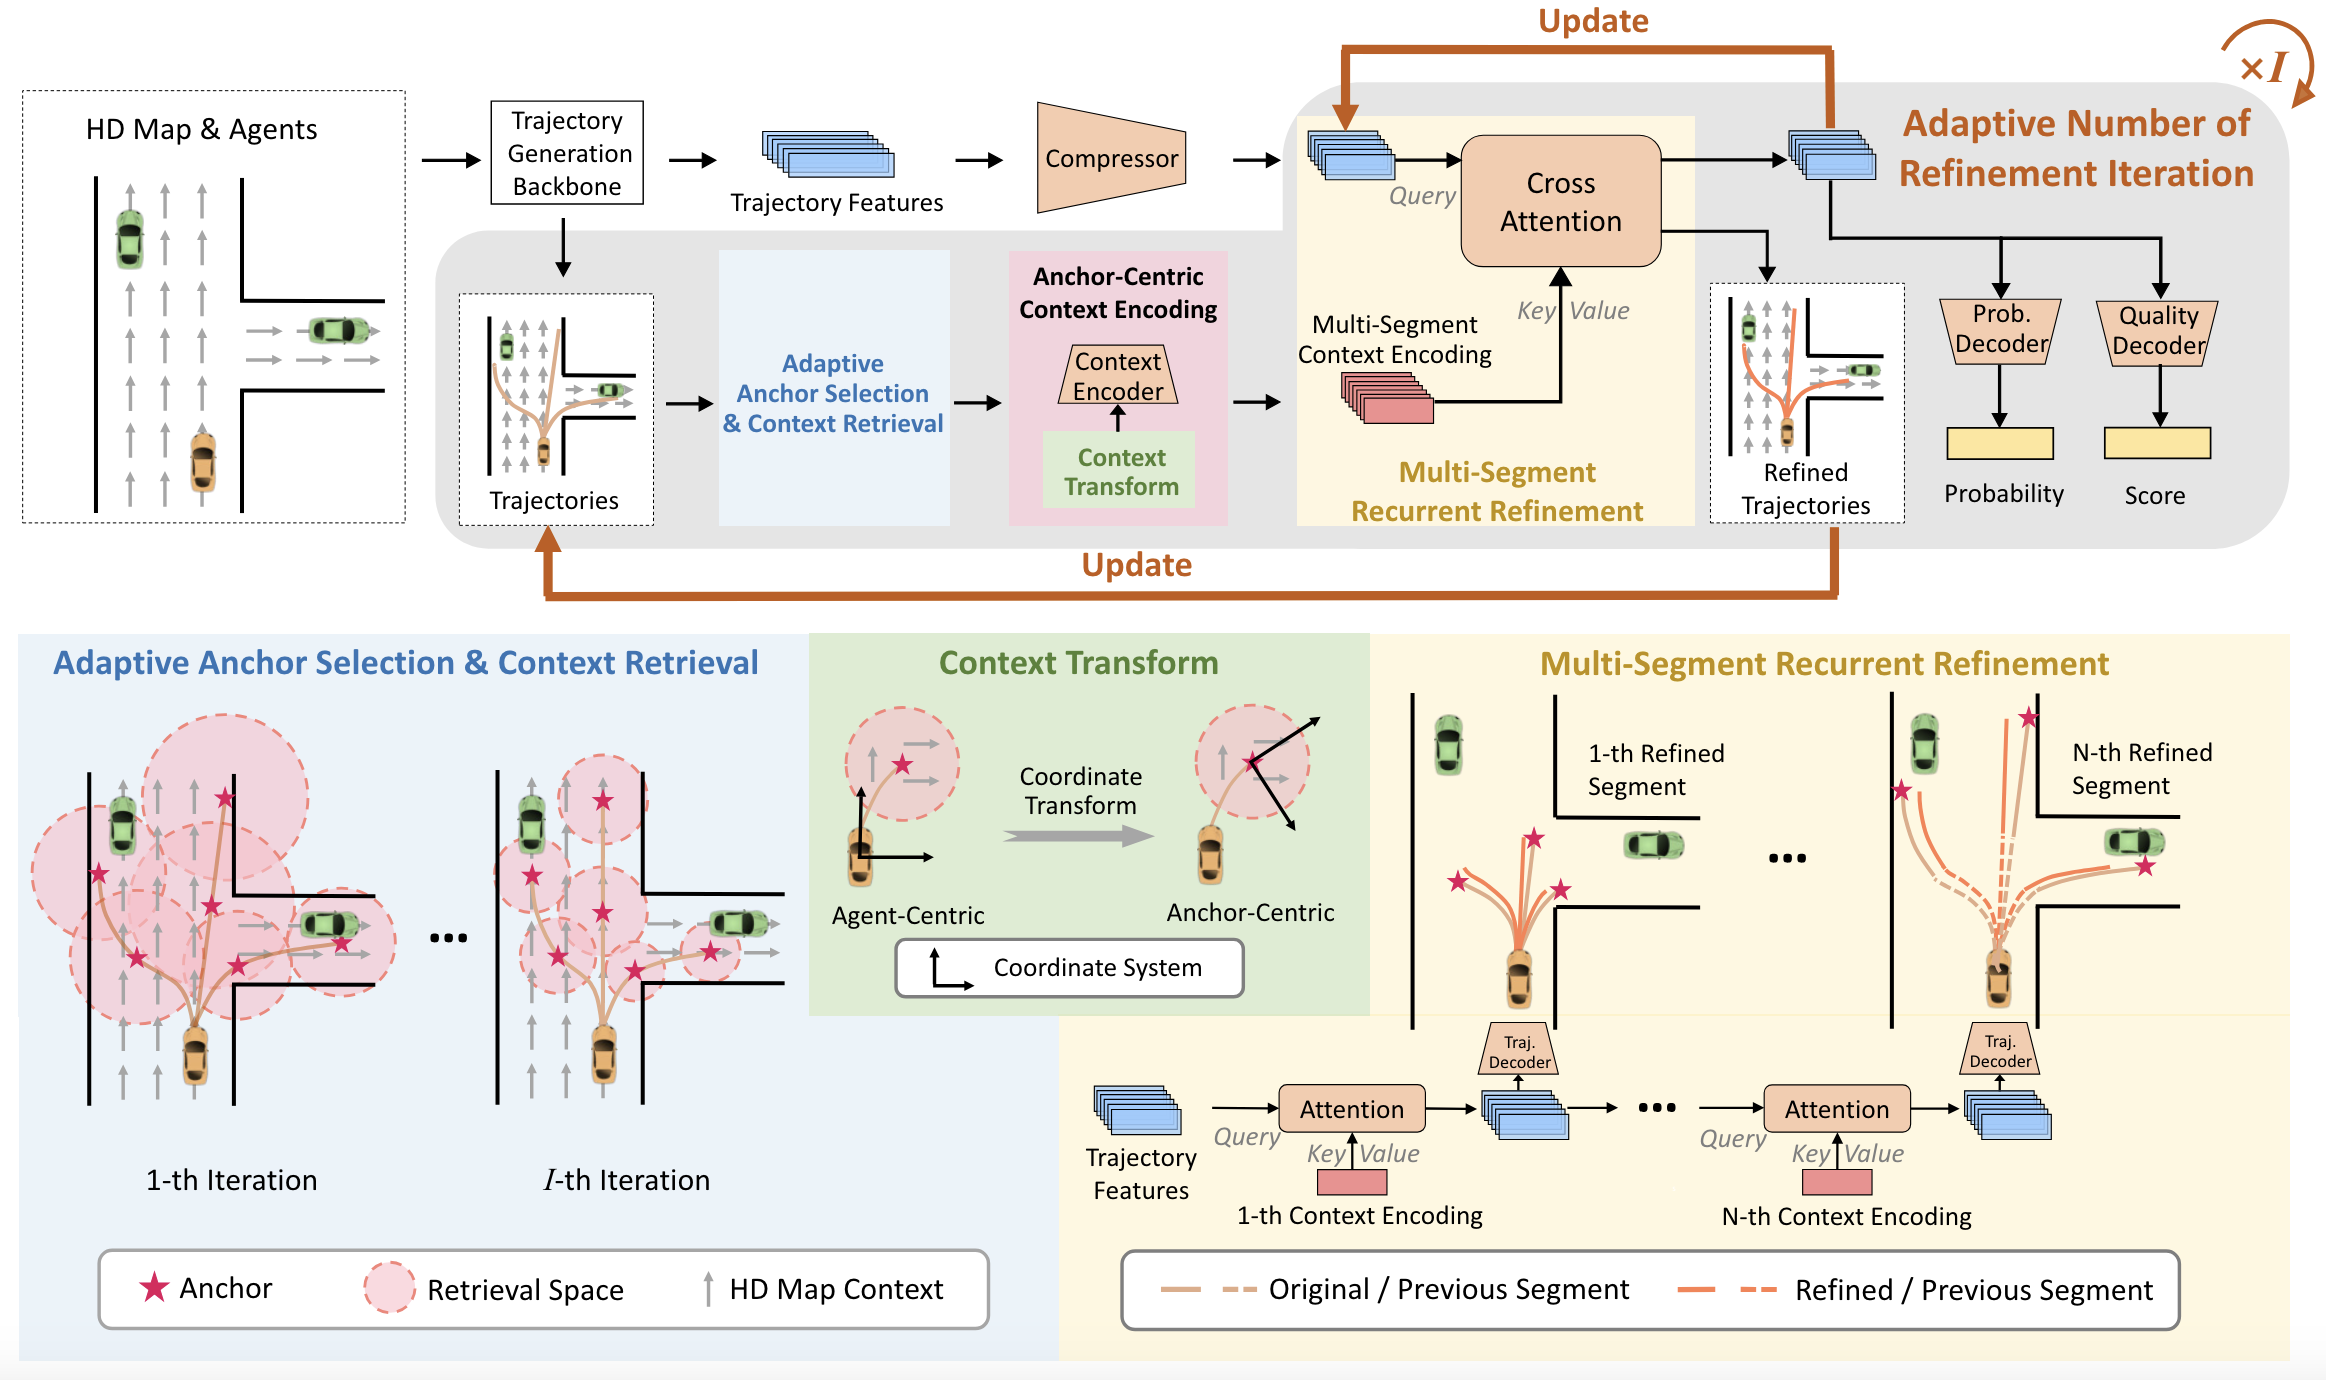
SmartRefine: An Scenario-Adaptive Refinement Framework for Efficient Motion Prediction
Yang Zhou, Hao Shao, Letian Wang, Steven L Waslander,
Hongsheng Li, Yu Liu
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR 2024)
Outperform all published ensemble-free works on Argoverse 2 leaderboard (single
agent track).
PDF •
Code
LmDrive: Closed-Loop End-to-End Driving with Large Language Models
Hao Shao, Yuxuan Hu, Letian Wang, Steven L Waslander,
Yu Liu, Hongsheng Li
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR 2024)
First work to bring LLM into closed-loop end-to-end autonomous
driving.
Webpage •
PDF •
Code
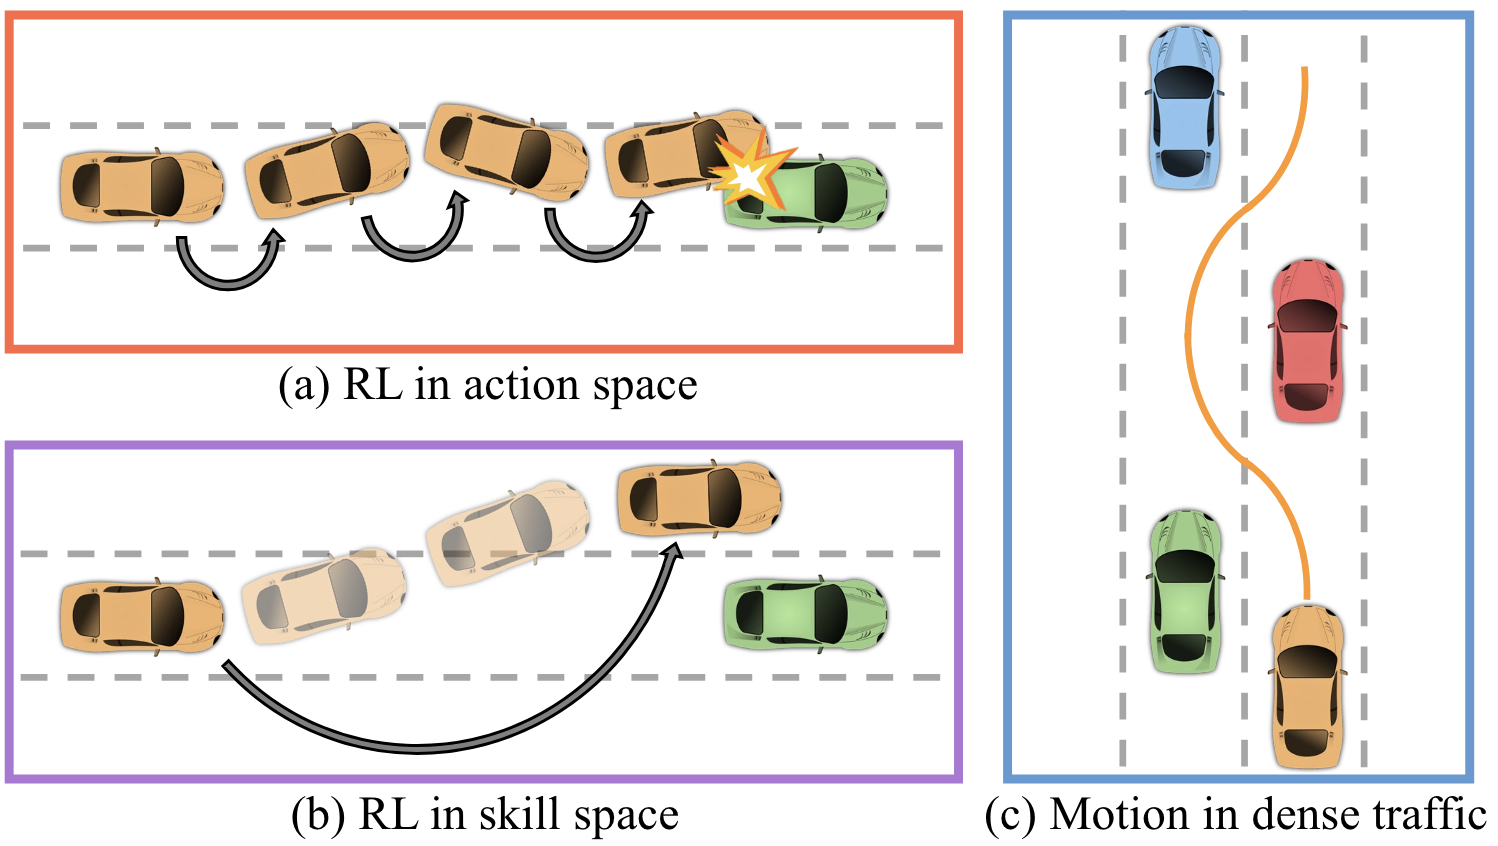
Accelerating Reinforcement Learning for Autonomous Driving using Task-Agnostic and Ego-Centric Motion Skills
Tong Zhou*, Letian Wang*, Ruobing Chen, Wenshuo Wang,
Yu Liu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2023)
PDF •
Efficient Reinforcement Learning for Autonomous Driving with Parameterized Skills and Priors
Letian Wang, Jie Liu, Hao Shao, Wenshuo Wang, Ruobing
Chen, Yu Liu, Steven L Waslander
Robotics: Science and Systems (RSS 2023)
PDF •
Code
Talk
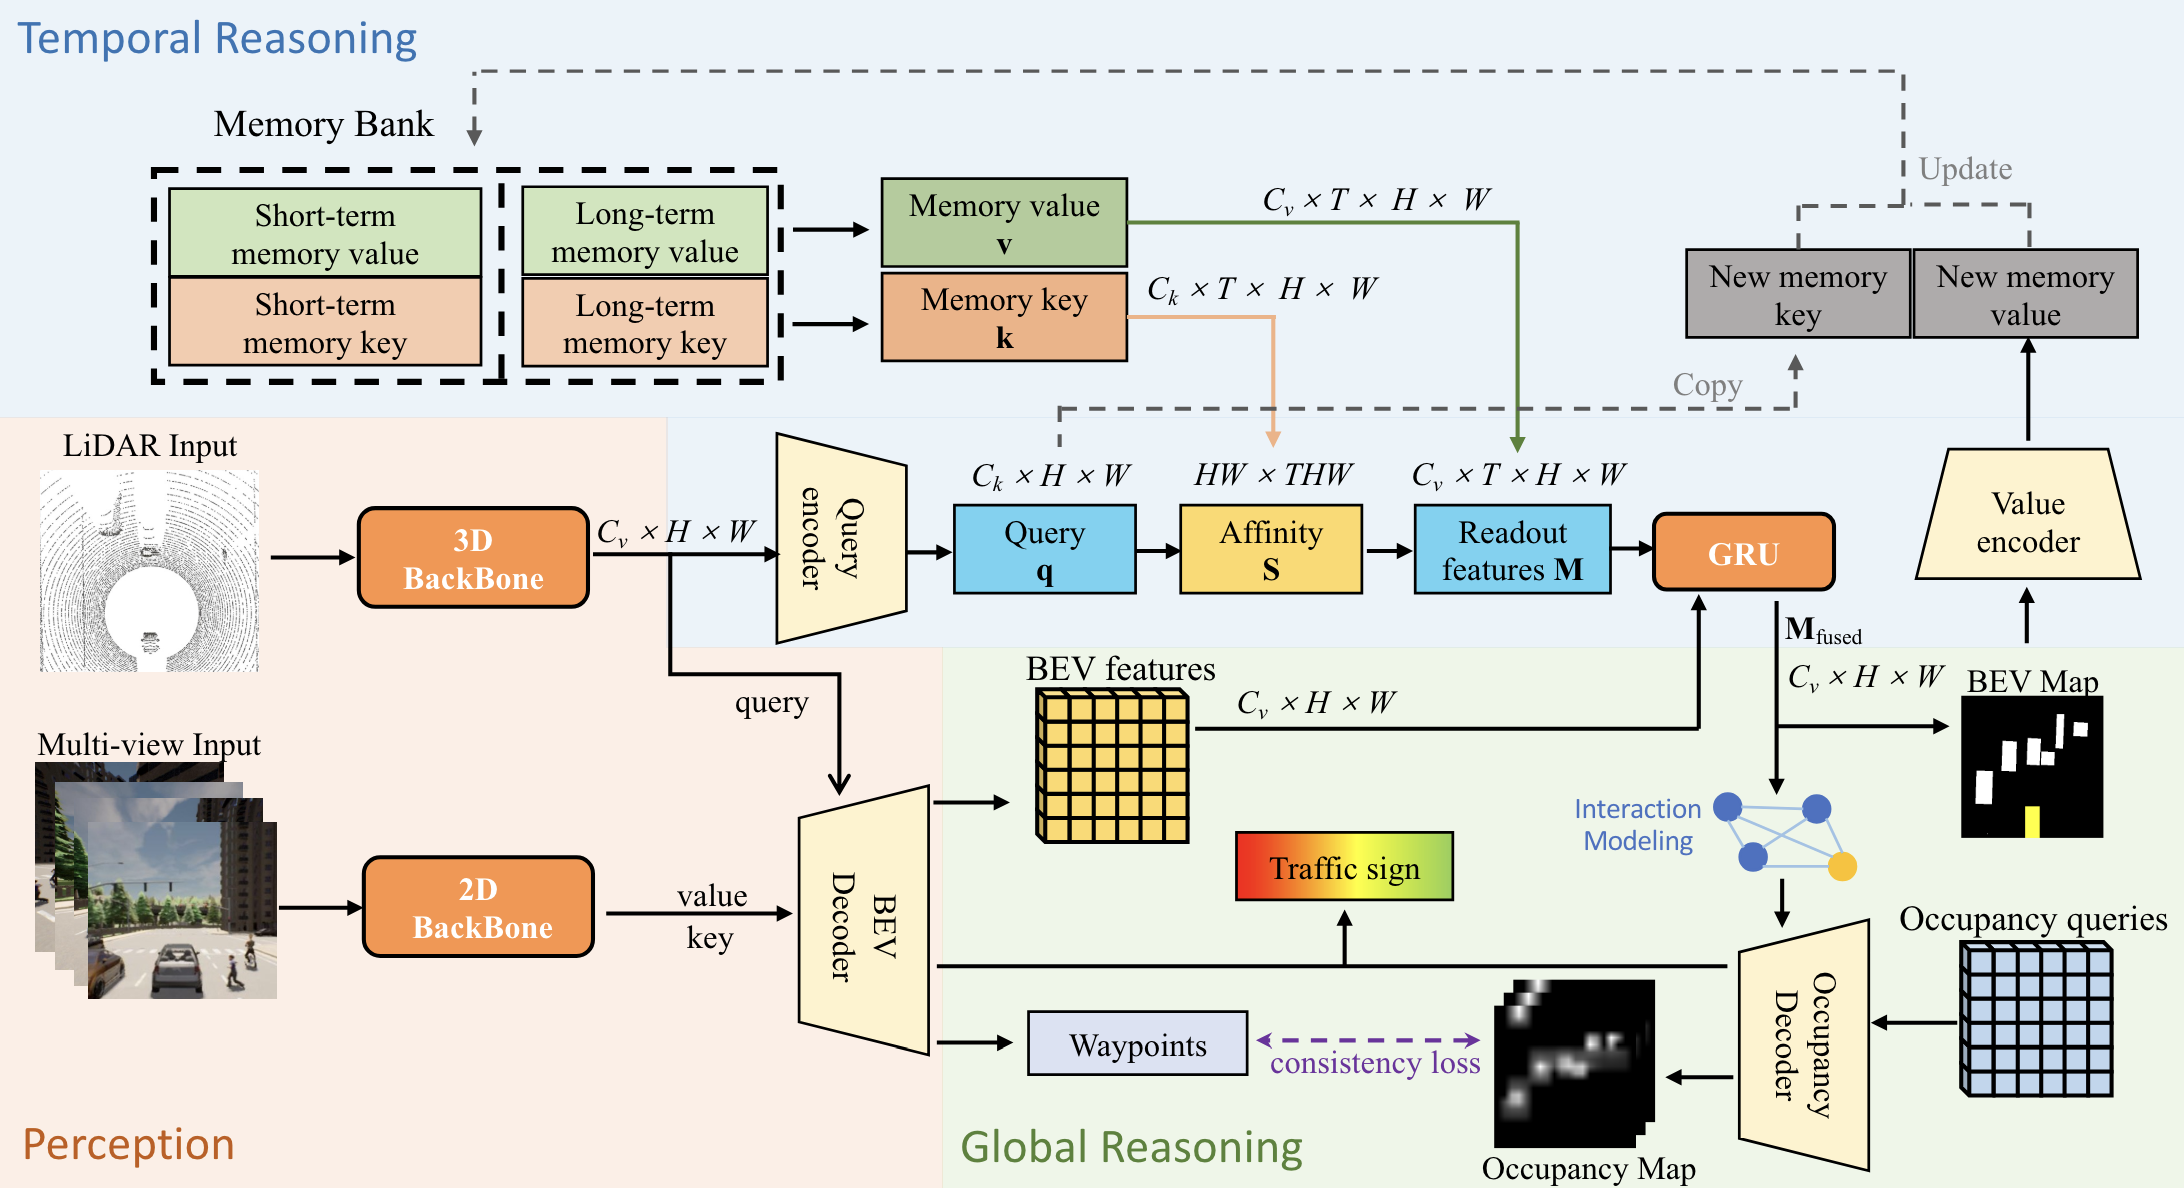
ReasonNet: End-to-End Driving with Temporal and Global Reasoning
Hao Shao, Letian Wang, Ruobing Chen, Steven L
Waslander, Hongsheng Li, Yu Liu
Conference on Computer Vision and Pattern Recognition (CVPR 2023)
Winner of CARLA Autonomous Driving Challenge 2022
PDF •
Code
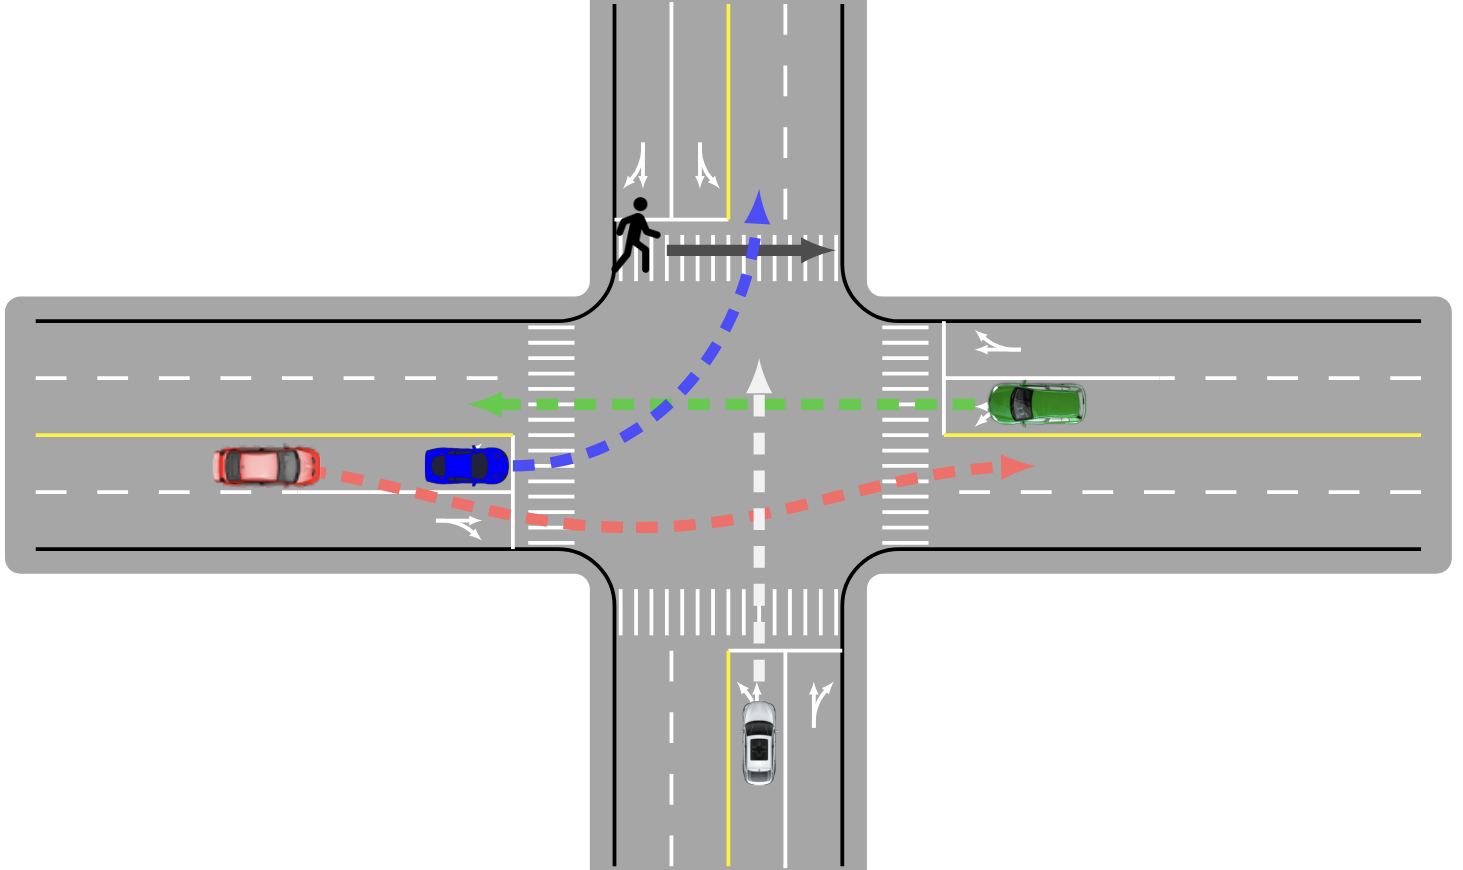
Social Interactions for Autonomous Driving: A Review and Perspectives
Wenshuo Wang, Letian Wang, Chengyuan Zhang, Changliu
Liu, Lijun Sun
Foundation and Trends in Robotics (Book)
PDF •
Safety-Enhanced Autonomous Driving Using Interpretable Sensor Fusion Transformer
Hao Shao*, Letian Wang*, Ruobing Chen, Hongsheng Li,
Yu Liu
Conference on Robot Learning 2022
First Place on the CARLA Leaderboard
PDF •
Code
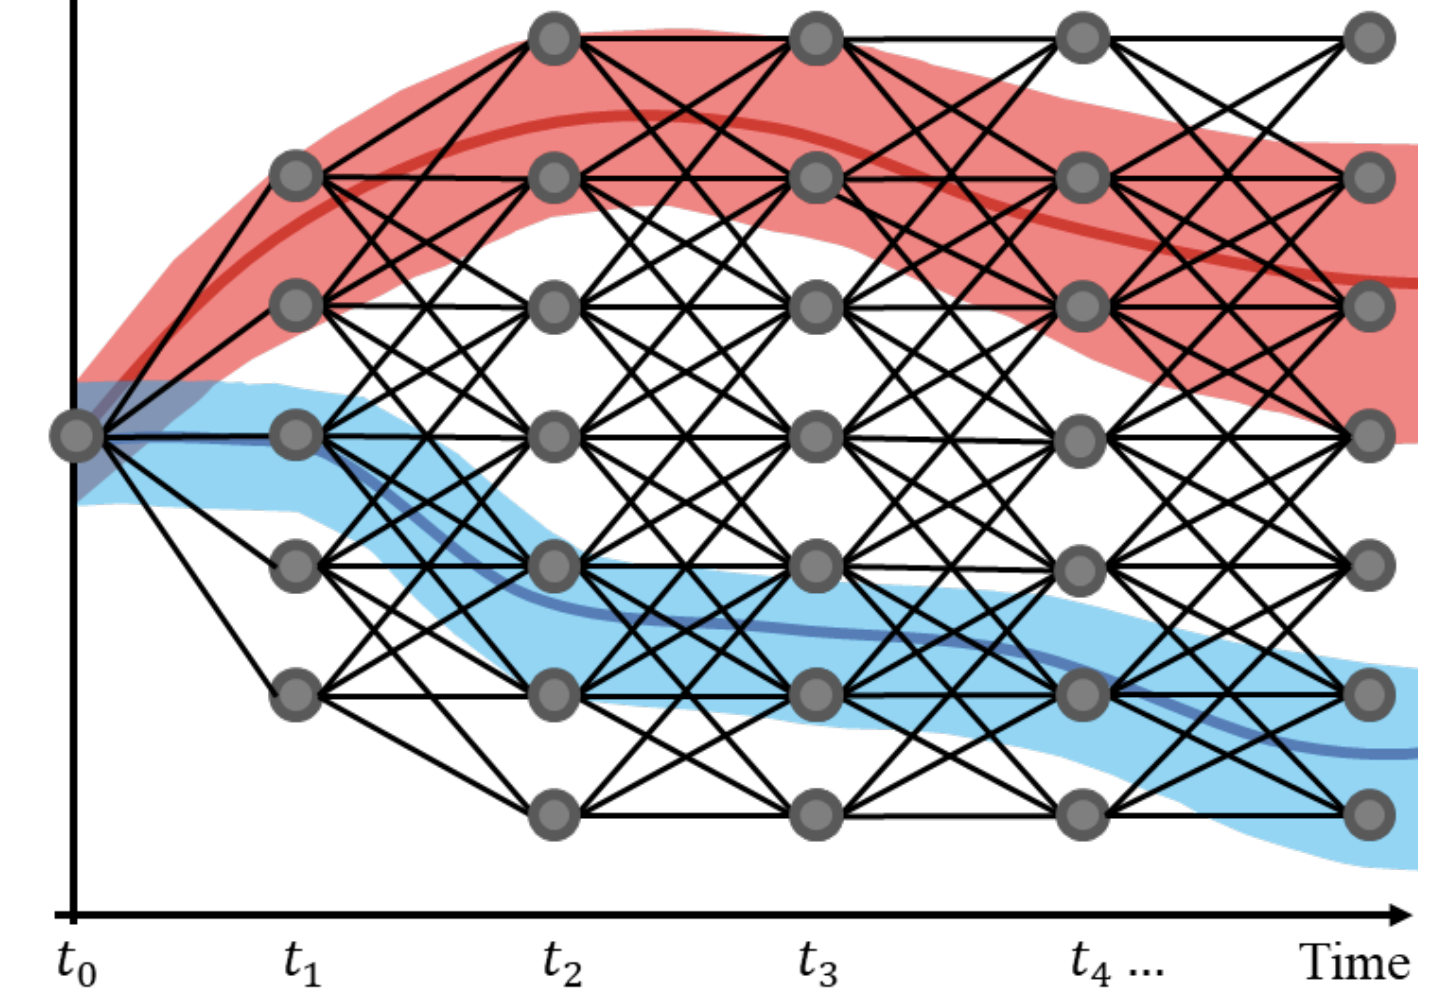
Efficient Game-Theoretic Planning with Prediction Heuristic for Socially-Compliant Autonomous Driving
Chenran Li, Tu Trinh, Letian Wang, Changliu Liu,
Masayoshi Tomizuka, Wei Zhan
IEEE Robotics and Automation Letters 2021
PDF •
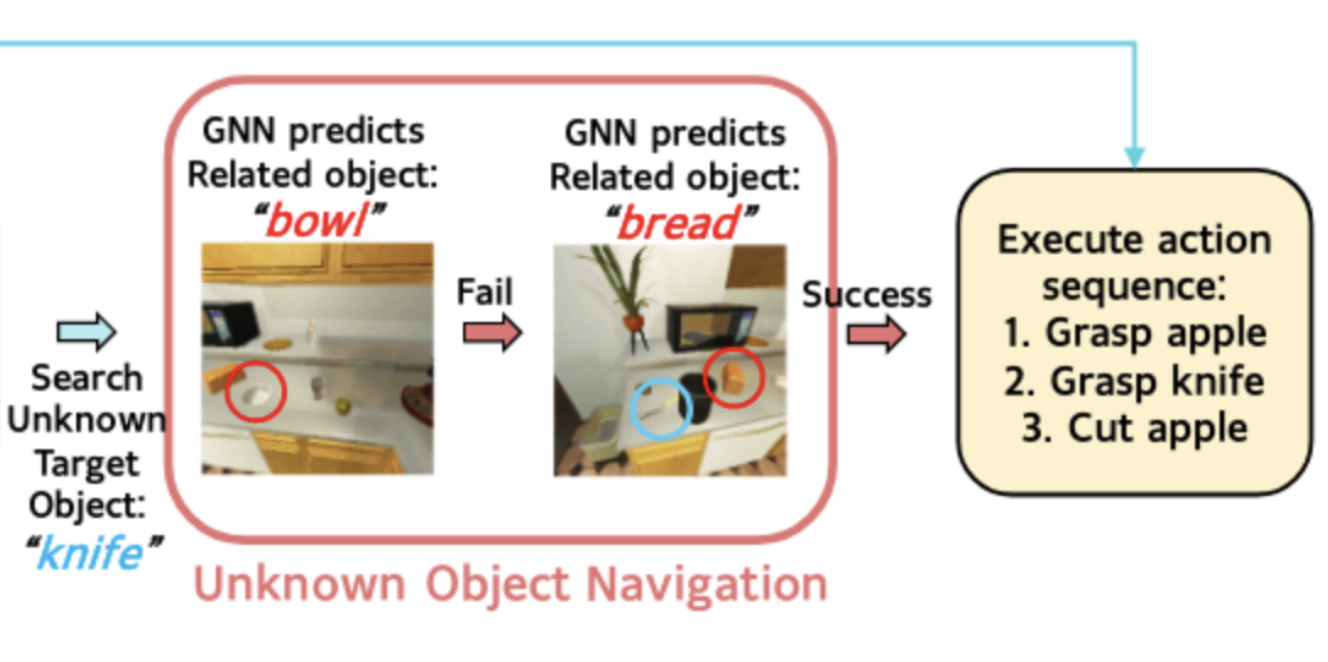
Human Instruction Following: Graph Neural Network Guided Object Navigation
Hongyi Chen, Letian Wang, Yuhang Yao, Ye Zhao,
Patricio Vela
The IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2022, Workshop on Embodied
AI
PDF •
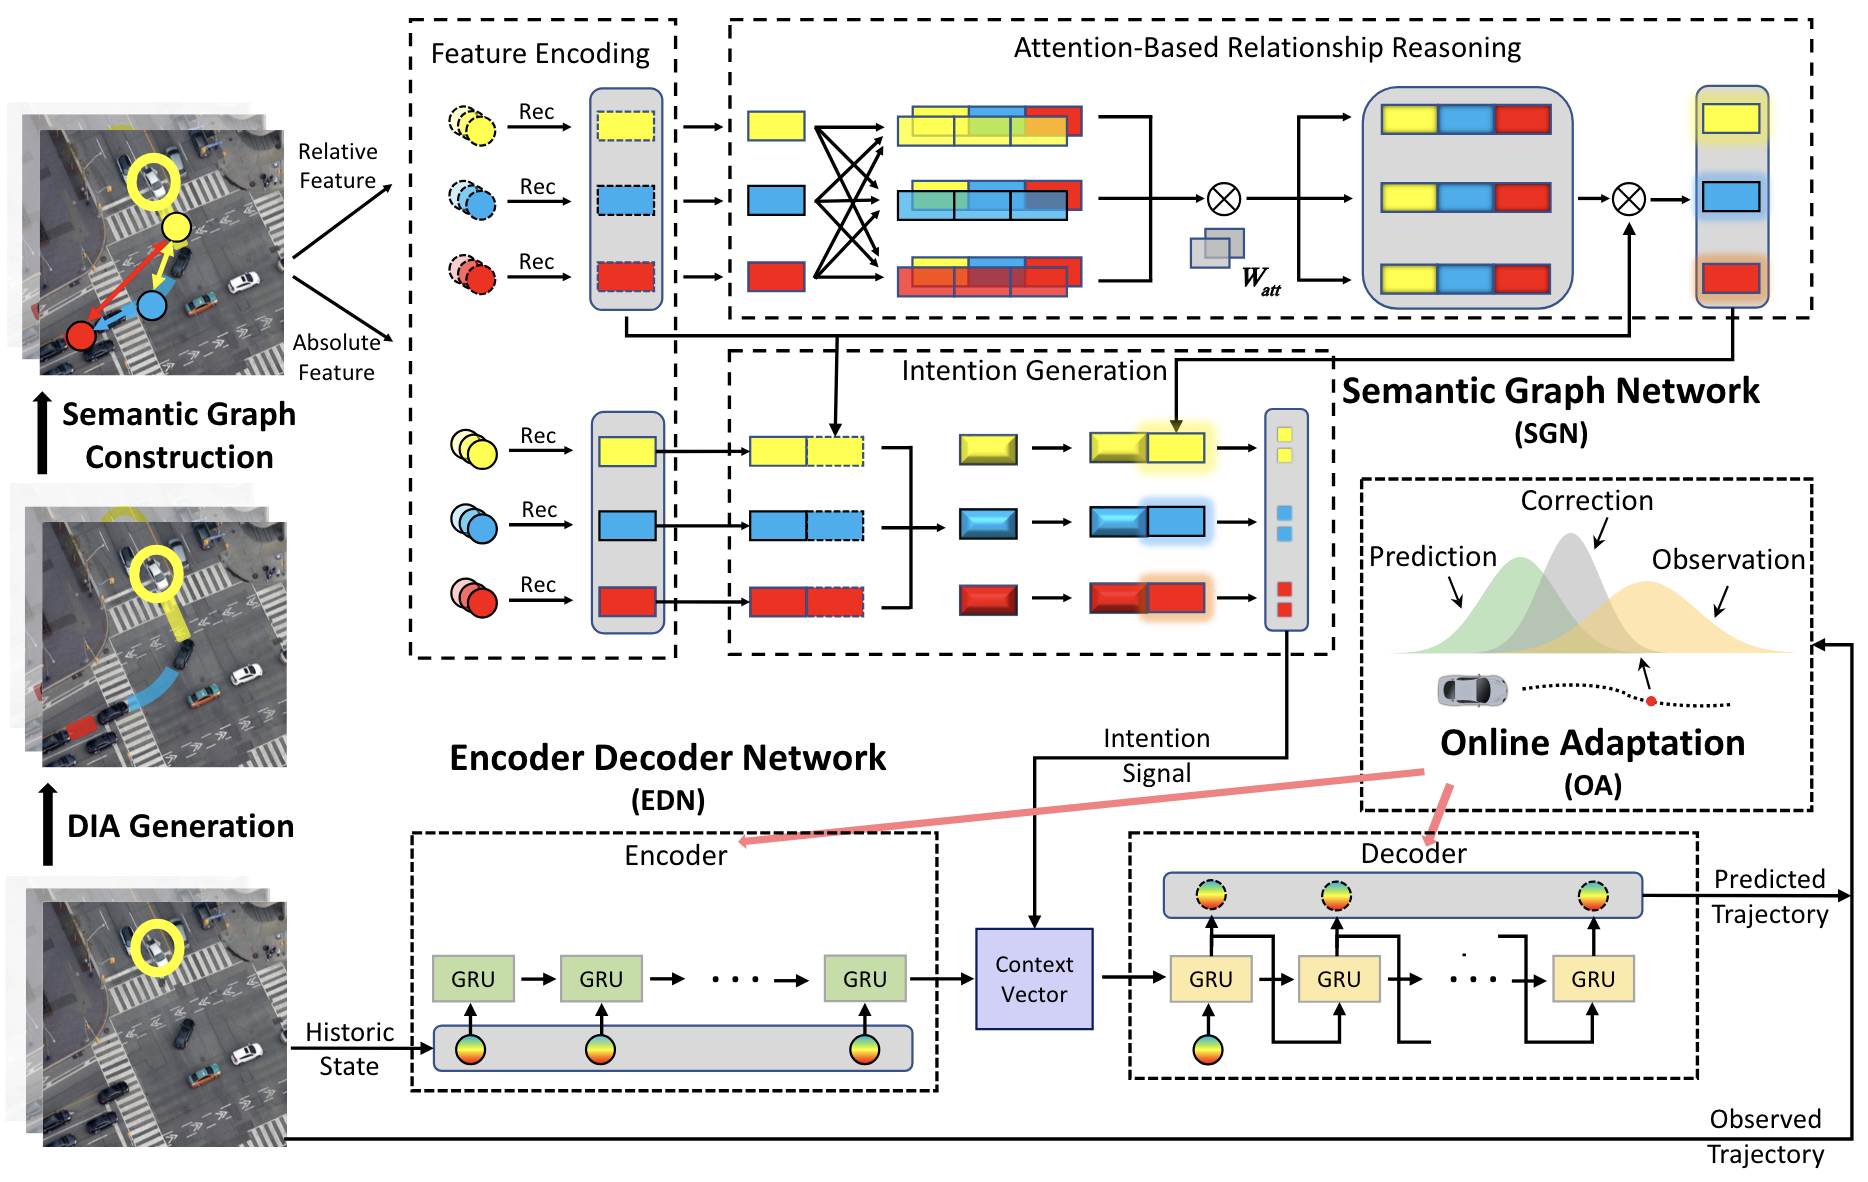
Transferable and Adaptable Driving Behavior Prediction
Letian Wang, Yeping Hu, Liting Sun, Wei Zhan,
Masayoshi Tomizuka, Changliu Liu
arxiv
PDF •
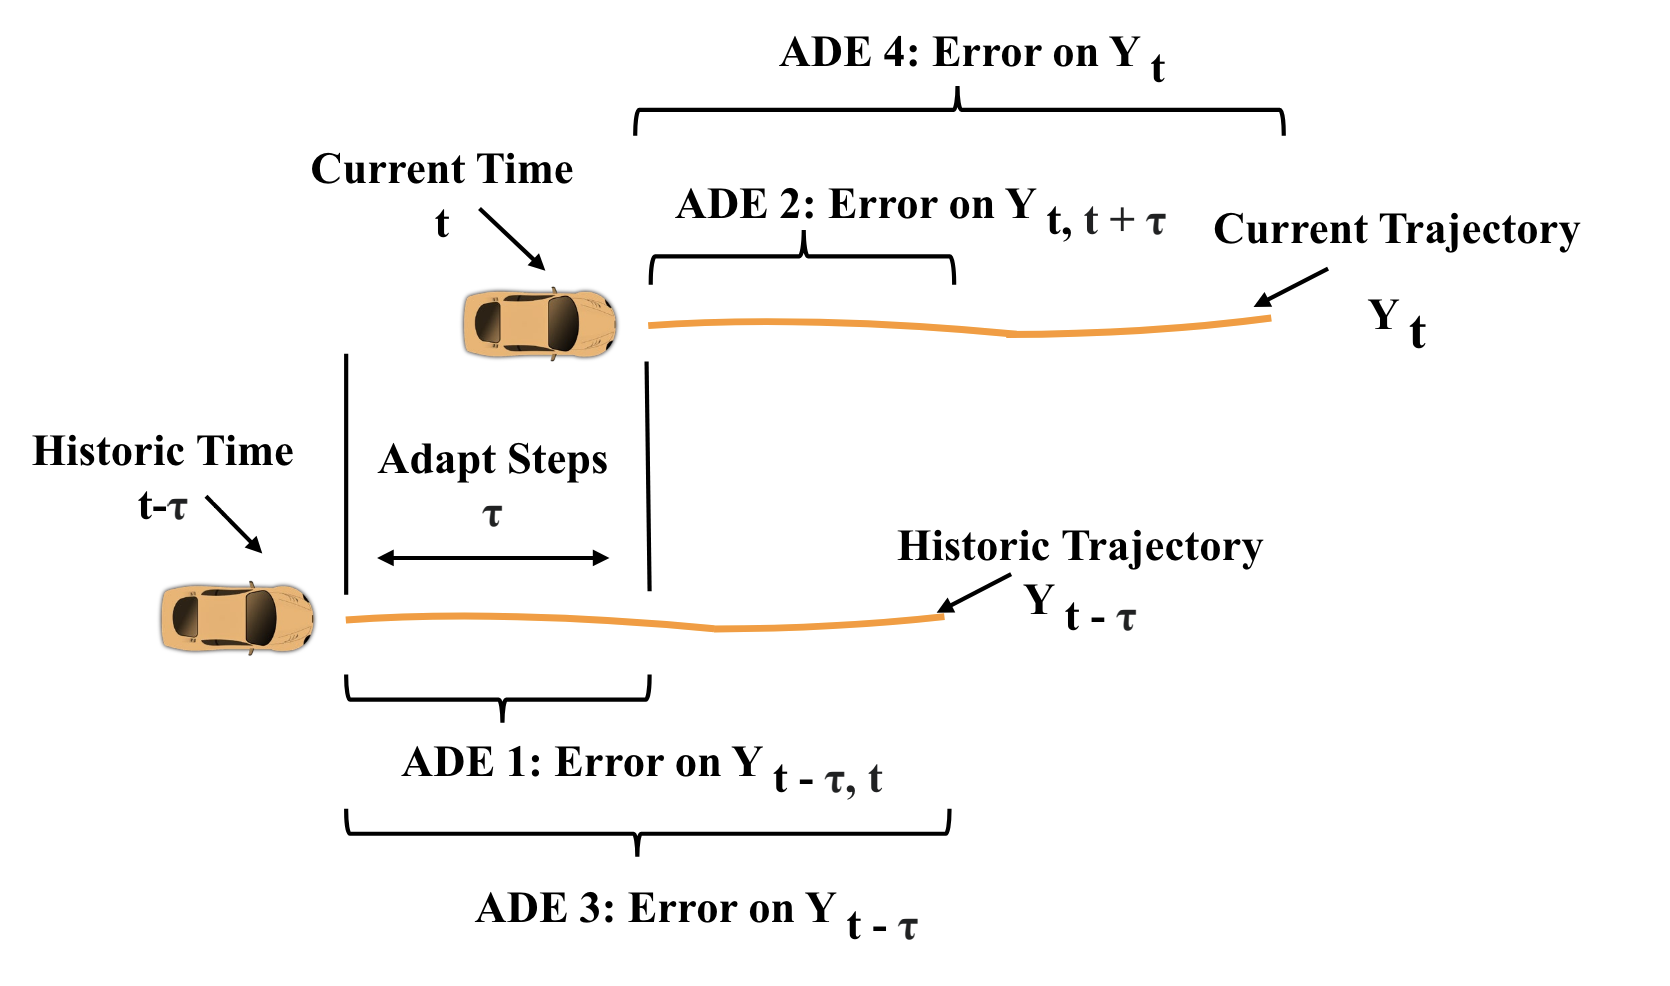
Online Adaptation of Neural Network Models by Modified Extended Kalman Filter for Customizable and Transferable Driving Behavior Prediction
Letian Wang, Yeping Hu, Changliu Liu
AAAI Conference on Artificial Intelligence, Workshop on Human-Centric Self-Supervised Learning
PDF •
Hierarchical Adaptable and Transferable Networks (HATN) for Driving Behavior Prediction
Letian Wang, Yeping Hu, Liting Sun, Wei Zhan,
Masayoshi Tomizuka, Changliu Liu
Conference on Neural Information Processing Systems (NeurIPS 2021), Workshop on Machine Learning for
Autonomous Driving (Spotlight)
PDF •
Socially-Compatible Behavior Design of Autonomous Vehicles with Verification on Real Human Data
Letian Wang, Liting Sun, Masayoshi Tomizuka, Wei
Zhan
IEEE Robotics and Automation Letters 2021 Best Paper Award - Honorable
Mention
PDF •
Overall Design and Control of Coaxial Tilt Rotor Vertically Take-off-and-Landing UAV
Letian Wang, Yuhan Lu, Yibo Liu, Yicong Fu, Bonan Xu, Jingyu Zhao, Qi Qian, Yifan Yan, Weijun Wang
First prize in National Challenge Cup 2017 (全国挑战杯一等奖, known as the Sci./Tech. Olympics among universities in China).
Some of my slides can be found here
2026
Invited talk on GenCeption at Universify of Oxford VGG Lab, Imperial College London, Tshinghua University, Galbot, Xiaomi, Nanyang Technological University2024
Toronto TechTalk
ZDX Public Course
2023
IV Workshop on Social Behavior for Autonomous Vehicle2021
NeurIPS Workshop on Machine Learning for Autonomous Driving2020
INFORMS Annual Meeting2024
Co-organizer, the 2nd International Workshop on Socially Interactive Autonomous Mobility (SIAM) at IV‘242023
Program Commitee, Machine Learning for Autonomous Driving Symposium at NeurIPS'23
Co-organizer, the 1st International
Workshop on Socially Interactive Autonomous Mobility (SIAM) at IV‘23
2022
Program Commitee, Workshop on Learning for Autonomous Driving at NeurIPS'222020+
Reviewer: IJRR, RSS, NeurIPS, CVPR, ICRA, IROS, ML4AD, TNNLS, TVT, ITS, IV